Euler's Equation
Last edited: August 8, 2025\begin{equation} f(x) = e^{ix} = \cos (x) + i\sin (x) \end{equation}
this brings a circle of radius one, because in every point, velocity is orthogonal to where you are (because \(f’(x) = if(x)\), and multiplying by \(i\) accounts for a rotation of 90 degrees.
And so,
\begin{equation} z = re^{i\theta} \end{equation}
gives any point in the imaginary polar plane.
Europe
Last edited: August 8, 2025evaluation
Last edited: August 8, 2025our ultimate goal is to create a generalized model that learns training data and extrapolate to future test data.
We don’t really care about how good we fit the training data.
key idea: fit the model on train set, and test on separate test set.
requirements
We split our training set into three parts
- training set: to fit the model
- validation set: quasi-test set
- test set: actual test (we do it only once)
additional information
root-mean-square error
this is basically least-squares error but with normalization
evaulating model fitness
Last edited: August 8, 2025We want to compare features of the model to features of the data:
Visual diagnostics
- PDF plot
- CDF of data vs. CDF of model
- Quantile-Quantile plot
- Calibration Plot
Summative Metrics
- KL Divergence
- Expected Calibration Error
- Maximum Calibration Error
Marginalization Ignores Covariances
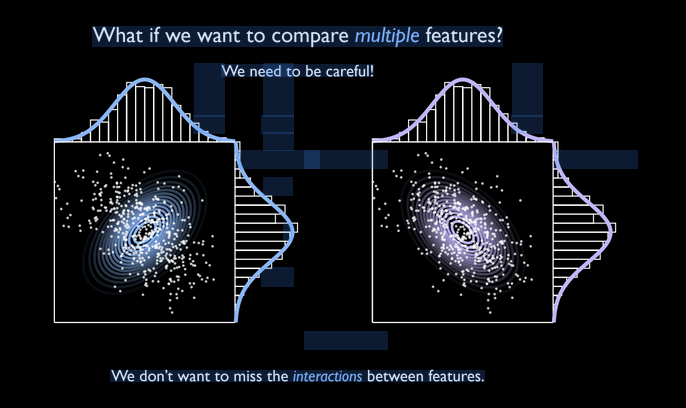
Notice on the figure on the right captures distribution much better, yet the marginal distributions don’t show this. This is because marginalizing over the datasets ignores the covariances. Hence, remember to keep dimensions and any projections hould capture covariances, etc.
event
Last edited: August 8, 2025An event is sub-subset of the sample space \(E \in S\). These are some subset to which you ascribe some meaning.